Explore the fundamental concepts of two-dimensional kinematics, including coordinate systems (Cartesian and Polar), vector notation (magnitude-direction and unit vector), and the separation of motion into independent horizontal and vertical components. Learn to analyze position and velocity vectors and understand vecto
In physics, describing the motion of an object requires more than just a single number. While one-dimensional motion can be described by a simple line, objects in the real world move through space, often changing both their horizontal and vertical positions simultaneously. To analyze this, we use vectors—mathematical entities that possess both a magnitude (size) and a direction. Mastering two-dimensional kinematics requires a deep understanding of how to represent these vectors using different coordinate systems and how to break them down into manageable parts.
Coordinate Systems: Cartesian and Polar
To locate a point or describe a vector in a plane, we must first establish a reference frame. Two primary systems are used in physics: Cartesian and Polar coordinates.
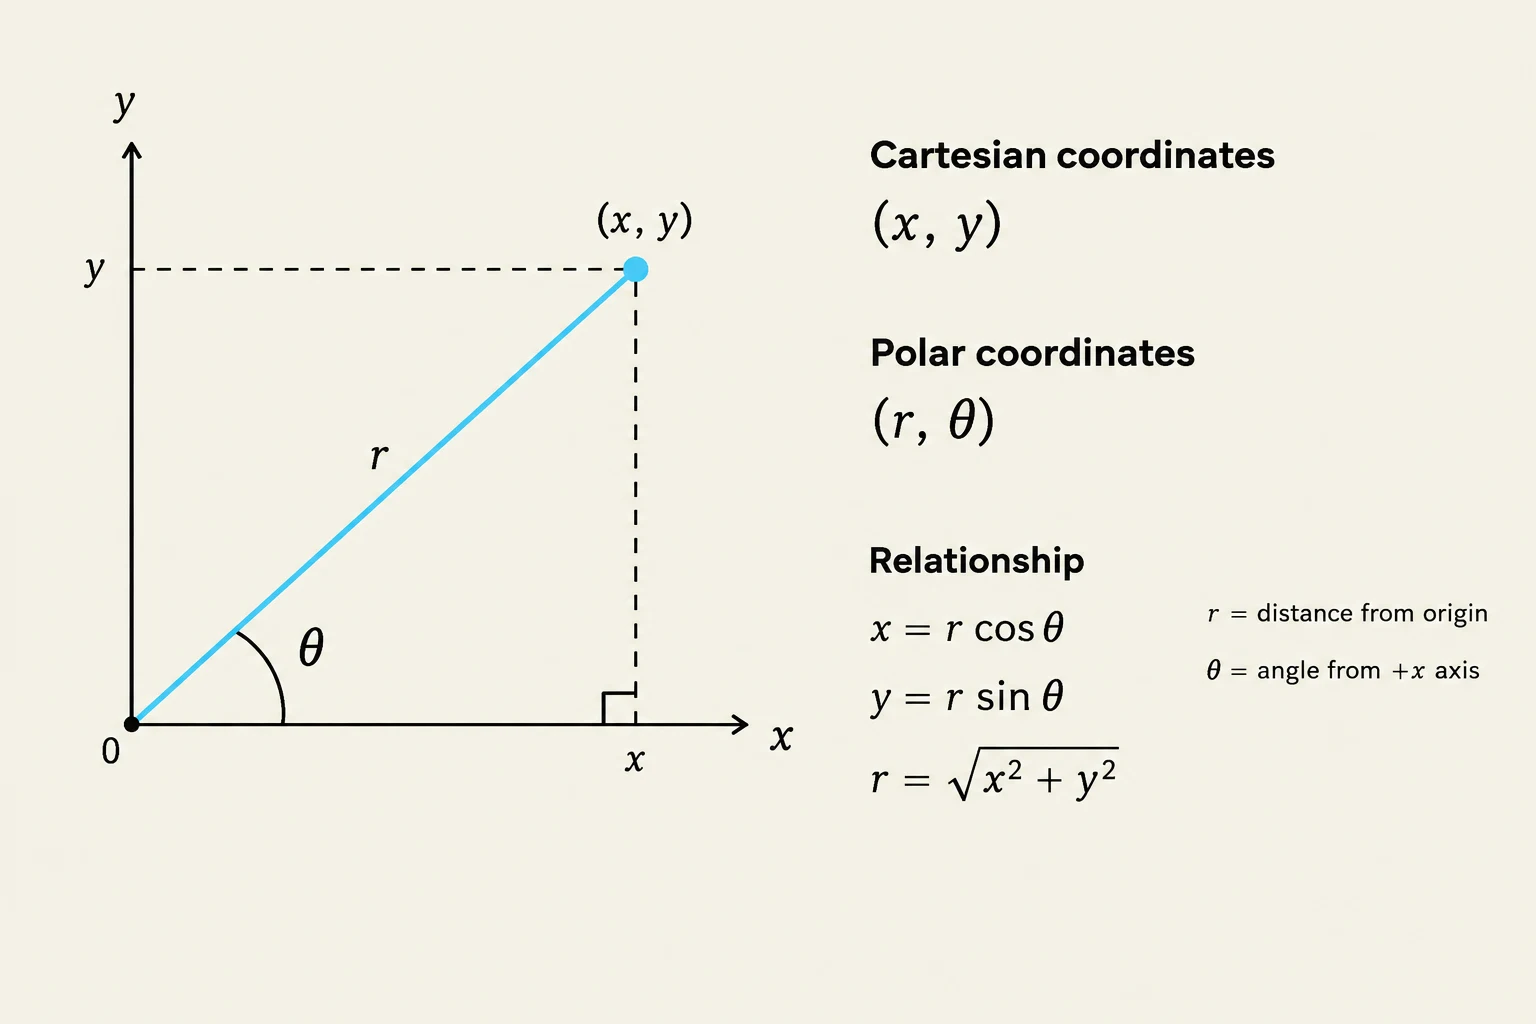
Cartesian coordinates use a grid of perpendicular axes, typically labeled x and y. A point is identified by its horizontal distance from the origin (x) and its vertical distance (y). This system is highly intuitive for describing rectangular motion.
Polar coordinates, on the other hand, describe a point using a distance r from the origin and an angle θ measured counterclockwise from the positive x-axis. Polar coordinates are exceptionally useful when dealing with radial motion, such as objects moving in circles or arcs, or when forces are specified by a fixed magnitude and a specific direction.
To convert between these two systems, we use trigonometry. If you know the polar coordinates (r,θ), you can find the Cartesian components using:
xy=rcosθ=rsinθ
Conversely, if you have the Cartesian coordinates (x,y), you can find the magnitude r using the Pythagorean theorem and the angle θ using the tangent function:
rθ=x2+y2=tan−1(xy)
Exam Tip: When calculating θ using tan−1(y/x), always check the signs of your x and y components to determine which quadrant the vector is in. The calculator might give you an angle in the wrong quadrant if you don't manually adjust for the signs of x and y.
This diagram illustrates the relationship between Cartesian coordinates (x, y) and polar coordinates (r, θ), including the conversion formulas.
Vector Notation and Components
Once we have a coordinate system, we need a way to write down our vectors. There are two common ways to express them: magnitude and direction notation, and unit vector notation.
Magnitude and Direction Notation
This is the most "natural" way to describe a vector in everyday language. For example, "a force of 10 N at an angle of 30∘." It is often written as (10 N,30∘).
Unit Vector Notation
In formal physics calculations, we use unit vector notation. This involves using the unit vectors i^ (pointing in the +x direction) and j^ (pointing in the +y direction). A vector A is written as:
A=Axi^+Ayj^
Where Ax and Ay are the components of the vector along the respective axes. Unit vector notation is incredibly powerful because it simplifies vector addition, subtraction, and multiplication.
Separation of Motion into Components
One of the most critical concepts in kinematics is the separation of motion into components. This principle states that the motion in the x-direction is independent of the motion in the y-direction.
For example, if a skydiver is falling and moving horizontally at the same time, you can calculate her vertical displacement using only her vertical velocity, without needing to worry about her horizontal speed. This allows us to take complex two-dimensional problems and turn them into two simple one-dimensional problems.
Analyzing Position and Velocity
In two dimensions, we track an object's movement using the position vector and the velocity vector.
Position Vector (r): This vector points from the origin to the current location of the particle. If an object's position changes over time, we describe it as r(t)=x(t)i^+y(t)j^.
Velocity Vector (v): This represents the rate of change of the position vector. Mathematically, it is the derivative of position with respect to time:
v=dtdr
In component form, this is v=vxi^+vyj^.
The Particle Under Constant Velocity Model
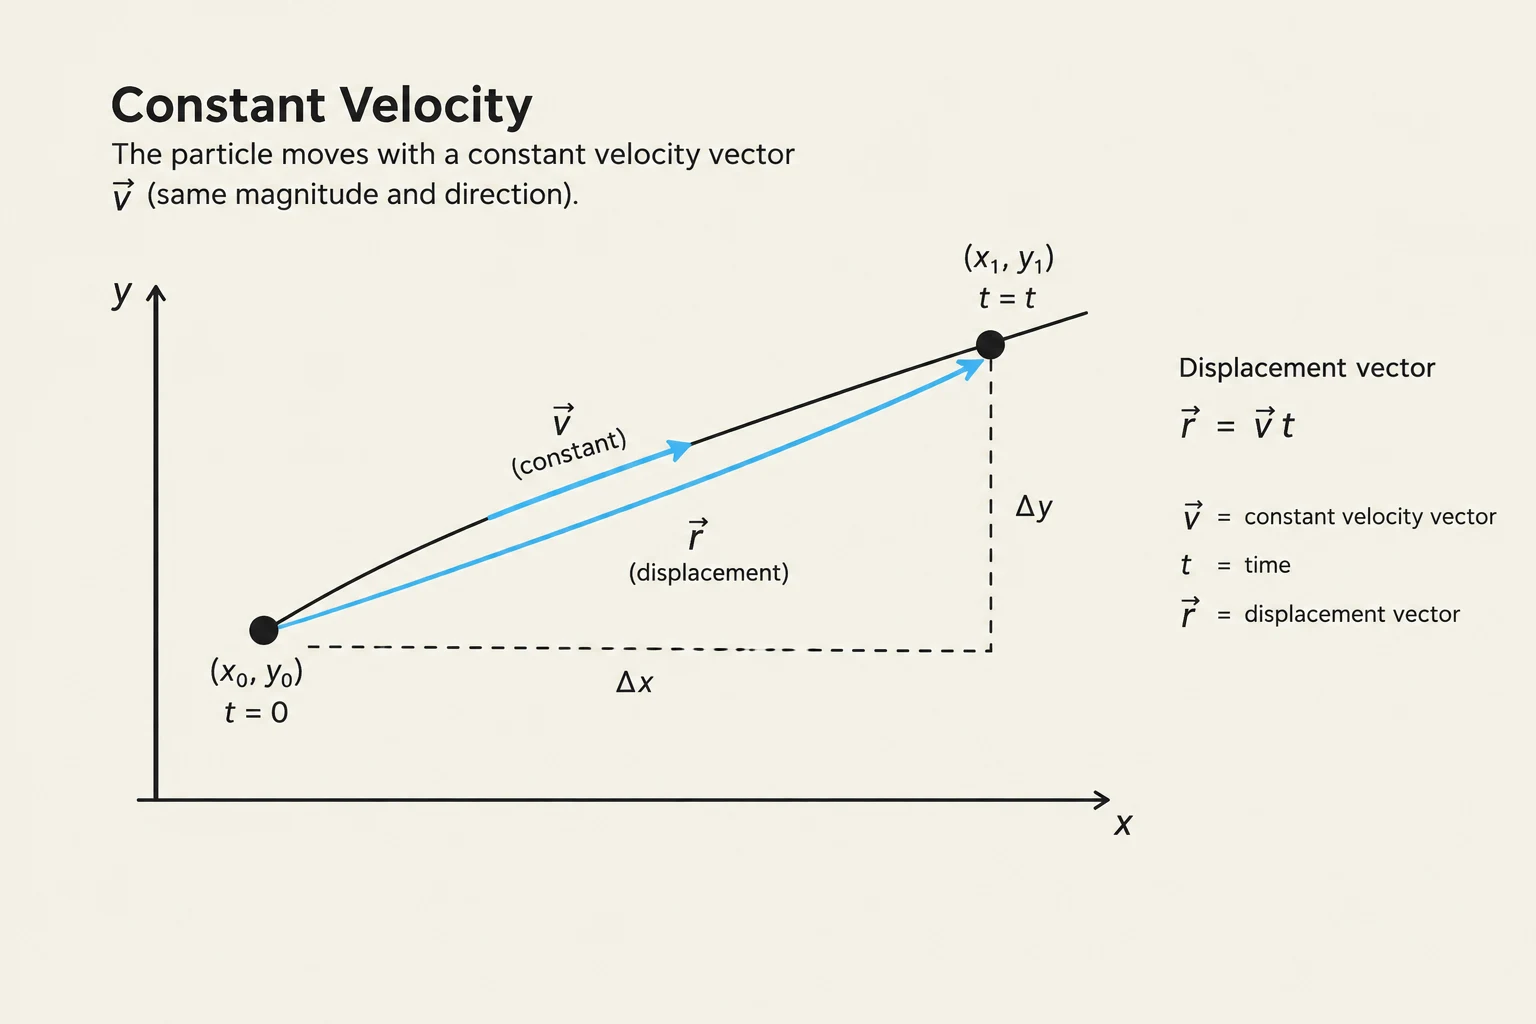
When an object moves such that its velocity vector does not change (neither its speed nor its direction), we use the particle under constant velocity model. In this model, the displacement Δr over a time interval Δt is simply:
Δr=vΔt
This can be broken down into components: Δx=vxΔt and Δy=vyΔt.
A diagram illustrating constant velocity motion, showing a particle moving from an initial position (x0, y0) at t=0 to a final position (x1, y1) at time t. The displacement vector r is shown, along with the constant velocity vector v.
Vector Addition and Geometry
When multiple vectors act on an object (like two people pulling on a mule), we find the resultant vector through two-dimensional vector addition. The most efficient way to add vectors is to add their corresponding components:
Atotal=(Ax+Bx)i^+(Ay+By)j^
In cases where vectors do not form a right triangle, we cannot use the simple Pythagorean theorem to find the magnitude of the resultant. Instead, we must use the Law of Cosines:
c=a2+b2−2abcosθ
This allows us to find the third side of any triangle if we know the lengths of the other two sides and the angle between them.
Summary Checklist for Vector Problems:
Identify the coordinate system (Cartesian or Polar).
Break all vectors into x and y components.
Perform your addition or subtraction using the components.
Convert the final resultant back into magnitude and direction if required.
Keep reading for free.
Create an account to finish this reading and make it part of your study routine.